
Article
Trigger Delay and Pulse Division on the Production Line with ALTRON
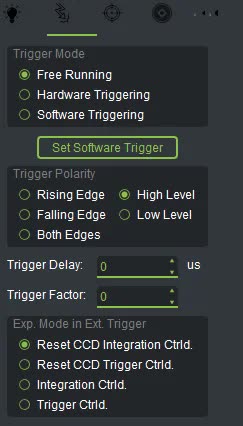
On a production line, the camera is commanded from outside by a trigger pulse. But the pulse does not always arrive at exactly the right moment and in the right number. Sometimes the part-detection sensor is mounted ahead of the field of view and the image is taken too early. Sometimes the encoder delivers more pulses than needed. There are two settings for these two problems: trigger delay and the pulse division factor. Both are on the Trigger tab of the camera panel and only take effect in Hardware Triggering mode.
First, know what each pulse captures
- In area scan cameras: Each pulse captures one full frame. Usually an optical sensor gives one pulse per part. Here, the precise timing of the pulse matters most.
- In line scan: Each pulse captures only one line. Usually an encoder on the conveyor roller supplies the pulses so that the line spacing is tied to the belt's movement. Here, the number of pulses per millimeter of movement matters most.
In practice, the detection sensor rarely sits exactly on the camera's line of sight. Lighting, the mounting frame or the camera housing take up the space, so the sensor is mounted further ahead. As a result, the area-scan camera captures an empty stretch of belt or half of a part. The solution is for the camera to wait a little after the pulse arrives.
This setting is called Trig. in Delay on the area-scan camera and Trigger Delay on the line-scan camera. Both are in microseconds.
Calculating it is a simple division: divide the distance from the sensor to the field of view by the belt speed. For example, if the distance is 5 centimeters and the belt moves at 0.5 meters per second, the required time is 0.1 seconds, that is, 100000 microseconds.
Enter this value, then fine-tune it while watching the image. If the part has not yet fully entered the frame, the image was taken too early and you need to increase the delay. If the part has already passed the middle of the frame, the image was taken too late and you need to reduce the delay.
Keep one limitation in mind: a time delay is only accurate when the belt speed is constant. If the line speed changes, you must recalculate this value too.
With encoder triggering, the line-scan camera captures one line for every fixed amount of belt travel. So if the belt slows down or speeds up, the image is not stretched or compressed. But sometimes the encoder delivers more pulses than you need, and the image is over-stretched in the direction of motion.
Trigger Factor divides the trigger frequency. For example, if you set it to 2, one line is captured for every two pulses. So you do not need to change the encoder; this setting thins out the pulses. This setting also exists on the area-scan camera under the name Trig. Factor.
- In the Trigger tab, set the mode to Hardware Triggering and choose the Trigger Polarity that matches the sensor or encoder output.
- Press Rst Trig Counts in the camera panel to reset the counter to zero.
- Start the belt and check in the Diagnostics tab whether Trigger Counter increases.
- With an encoder and a line-scan camera: compare Trigger Rate with the line rate you need. Then set Trigger Factor so that the trigger rate comes close to the required rate.
- With an optical sensor and an area-scan camera: calculate the delay from the distance and speed and enter it in Trig. in Delay.
- Run a few parts through and check where each part sits in the image. Adjust the delay up or down until the part sits in the right place in the frame.
A short general reference on rotary encoders: Wikipedia (English).
See the models on the pages line scan cameras and area scan cameras. If the sensor and encoder arrangement on your line is more complex than this example, via contact page and we will work it out together.